 PluginStats
mcp/ros2 pulls statistics
By mcp (100 listings) · Docker Hub · Machine learning & AI
Python server implementing Model Context Protocol (MCP) for ROS2.
mcp/ros2 has 14,342 recorded pulls on Docker Hub, ranking #799 of 1,265 tracked listings.
About mcp/ros2
WiseVision ROS2 MCP Server
Python server implementing Model Context Protocol (MCP) for ROS2.
MCP Info
| Attribute | Details |
|---|---|
| Docker Image | mcp/ros2 |
| Author | wise-vision |
| Repository | https://github.com/wise-vision/mcp_server_ros_2 |
Image Building Info
| Attribute | Details |
|---|---|
| Dockerfile | https://github.com/wise-vision/mcp_server_ros_2/blob/a4d248c63980e1304c3c5a3288ee165f880e59f4/Dockerfile |
| Commit | a4d248c63980e1304c3c5a3288ee165f880e59f4 |
| Docker Image built by | Docker Inc. |
| Docker Scout Health Score | |
| Verify Signature | COSIGN_REPOSITORY=mcp/signatures cosign verify mcp/ros2 --key https://raw.githubusercontent.com/docker/keyring/refs/heads/main/public/mcp/latest.pub |
| Licence | Mozilla Public License 2.0 |
Available Tools (14)
| Tools provided by this Server | Short Description |
|---|---|
ros2_action_request_result | Wait for the RESULT of a ROS 2 action (GetResult) for a given goal_id. |
ros2_action_subscribe_feedback | Subscribe to feedback messages of a ROS 2 action. |
ros2_action_subscribe_status | Subscribe to '/<action>/_action/status' (action_msgs/msg/GoalStatusArray) and return a snapshot of status frames over a time window. |
ros2_cancel_action_goal | Cancel a ROS 2 action goal via '/<action>/cancel_goal' (action_msgs/srv/CancelGoal). |
ros2_get_message_fields | Returns the fields of a given ROS2 message type. |
ros2_get_messages_stored_in_influx_data_base | Calls the ROS2 ‘/get_messages’ service to retrieve past messages from a topic for data which is stored in InfluxDB. |
ros2_interface_list | Returns a list of available ROS 2 interfaces. |
ros2_list_actions | List all available ROS 2 actions with their types and request fields. |
ros2_send_action_goal | Send a goal to a ROS 2 action by name and action type using provided goal fields. |
ros2_service_call | Call a ROS 2 service by name and type using provided fields. |
ros2_service_list | Returns a list of available ROS 2 services and their request fields. |
ros2_topic_list | Returns a list of available ROS 2 topics and their types. |
ros2_topic_publish | Publish a message to a ROS 2 topic by name and message type using provided field values. |
ros2_topic_subscribe | Subscribe to a ROS 2 topic by name collecting messages for a given time or count limit. |
Tools Details
Tool: ros2_action_request_result
Wait for the RESULT of a ROS 2 action (GetResult) for a given goal_id. Before every use of this tool, the agent should ensure the target action exists (e.g., by calling 'ros2_list_actions').
| Parameters | Type | Description |
|---|---|---|
action_name | string | Action name, e.g. '/fibonacci' |
action_type | string | Full action type, e.g. 'example_interfaces/action/Fibonacci' or 'pkg/ActionName' |
goal_id_hex | string | 32-char UUID hex of the goal (no dashes). |
timeout_sec | string optional | Seconds to wait for GetResult; null → wait indefinitely. |
wait_for_service_sec | number optional | Seconds to wait for the GetResult service to appear. |
Tool: ros2_action_subscribe_feedback
Subscribe to feedback messages of a ROS 2 action. Optionally filter by goal_id_hex. Collects feedback for a fixed duration or until a maximum number of messages is received. Each message contains goal_id, feedback payload, and receive timestamp.
| Parameters | Type | Description |
|---|---|---|
action_name | string | Action name, e.g. '/fibonacci' |
action_type | string | Full action type, e.g. 'example_interfaces/action/Fibonacci' or 'pkg/ActionName' |
duration_sec | number optional | How many seconds to keep spinning and collecting feedback. |
goal_id_hex | string optional | Optional 32-char UUID hex of the goal (no dashes) to filter feedbacks. |
max_messages | integer optional | Maximum number of feedback messages to collect. |
Tool: ros2_action_subscribe_status
Subscribe to '/<action>/_action/status' (action_msgs/msg/GoalStatusArray) and return a snapshot of status frames over a time window. Each frame contains goal_id, accept_stamp, status_code and status text.
| Parameters | Type | Description |
|---|---|---|
action_name | string | Action name, e.g. '/fibonacci' |
duration_sec | number optional | How many seconds to collect status frames. |
max_messages | integer optional | Max number of individual statuses to collect in total. |
Tool: ros2_cancel_action_goal
Cancel a ROS 2 action goal via '/<action>/cancel_goal' (action_msgs/srv/CancelGoal). You can cancel a specific goal by goal_id_hex or cancel all matching goals using cancel_all=True. Optionally limit cancellation to goals accepted before a given stamp (sec/nanosec). Before every use of this tool, the agent should ensure the target action exists (e.g., by calling 'ros2_list_actions').
| Parameters | Type | Description |
|---|---|---|
action_name | string | Action name, e.g. '/fibonacci' or '/navigate_to_pose' |
cancel_all | boolean optional | If true, send zero-UUID to cancel all matching goals. |
goal_id_hex | string optional | 32-char UUID hex of the goal (no dashes). Omit when cancel_all=True. |
stamp_nanosec | integer optional | Nanoseconds part for the acceptance time filter. |
stamp_sec | integer optional | Cancel goals accepted BEFORE this sec (default 0 → usually all). |
wait_timeout_sec | number optional | Timeout (seconds) to wait for the service and response. |
Tool: ros2_get_message_fields
Returns the fields of a given ROS2 message type.
| Parameters | Type | Description |
|---|---|---|
message_type | string | Full ROS2 message type, e.g., std_msgs/msg/String… |
Description from the Docker Hub listing.
README badge
Show your rank in a README or on your website. The badge updates automatically.
Charts
Images: 30d · 1y · all time · 1600×900 dark


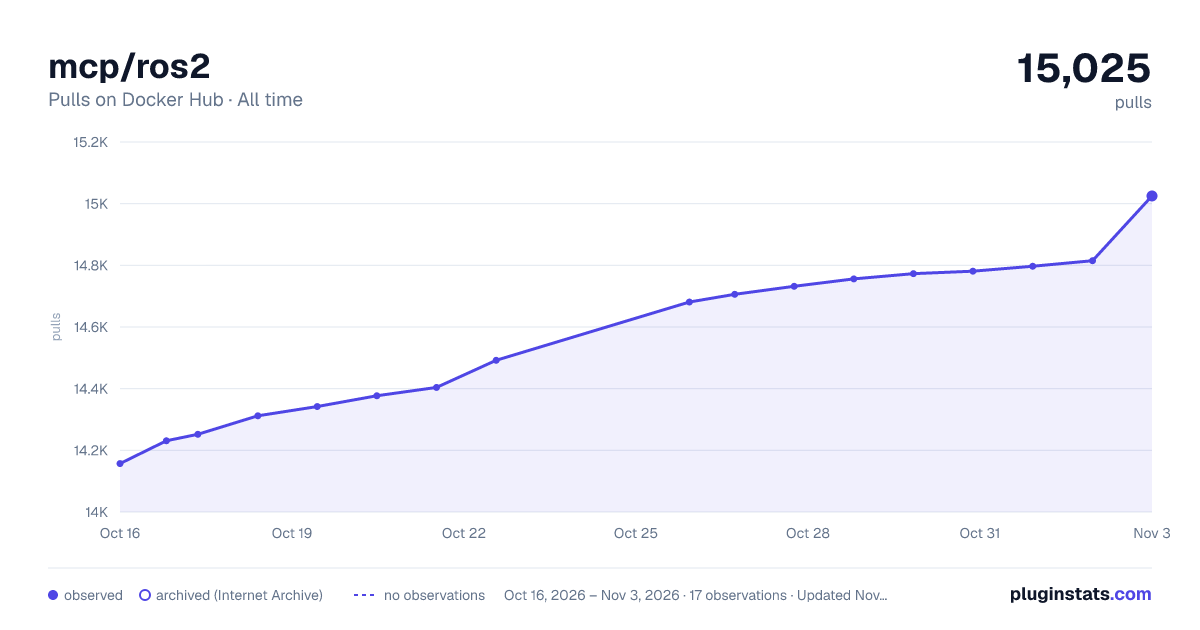

Adoption over time
7/30/90-day growth
Ranking history
Listing placement
Listing placement
Filled points are observed values; hollow points come from Internet Archive snapshots of the listing page. Dashed segments span periods with no observations — values between points are not interpolated.
Each band is one page of 20. Pulls on a linear scale. Placement is projected from pulls, so it can differ from the marketplace's own sort order. Hover a dot to see the listing.
Recent observations
Full history (5)Similar Docker Hub Machine learning & AI plugins
All 20 mcp/ros2 alternativesData source
Cumulative pull counts and stars come from the public Docker Hub API. Pulls count image downloads (including automated CI pulls), not installs or users.
Listing: https://hub.docker.com/r/mcp/ros2. First seen Oct 16, 2026; last successful collection Oct 20, 2026. See the methodology.